Coming soon Powered by SimRig · 003
Humanoid Whole-Body Control
Coordinated balance, locomotion, and manipulation for a full-body humanoid policy.
- Control
- Whole body
- Robot
- Humanoid
- Status
- In development
DAIONICS SPACES
Enter our robot learning environments. Each space is a window into a task, a policy, and the behavior taking shape between them. Live robot experiments built, trained, and streamed with SimRig.
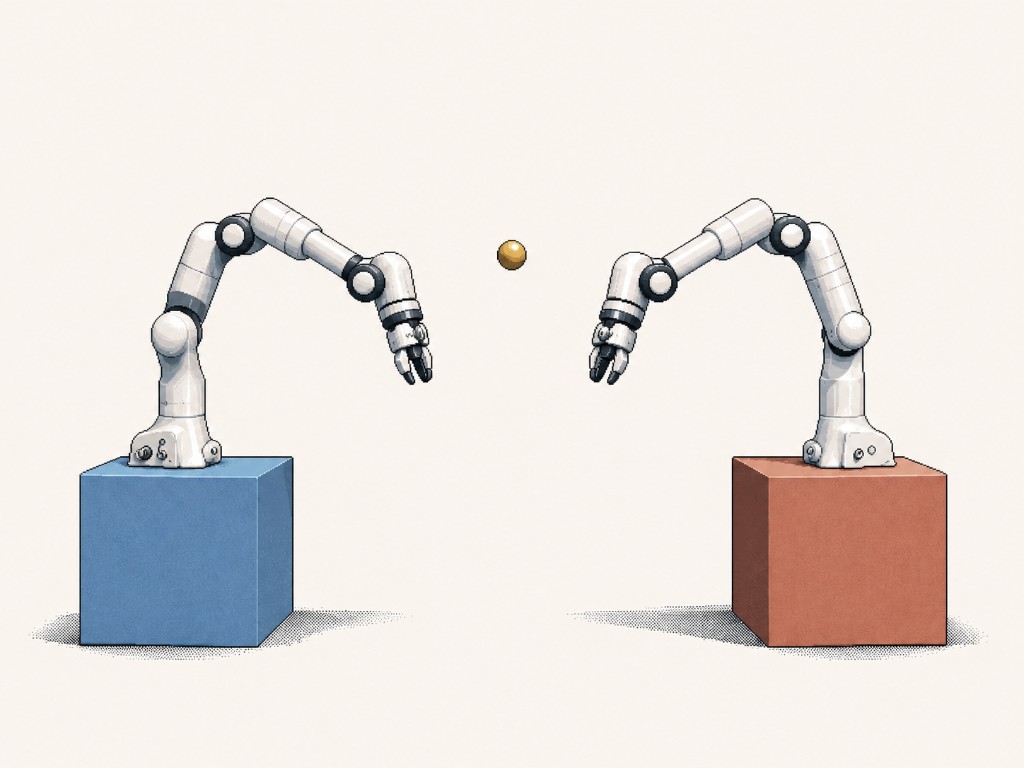
Two Franka Pandas exchange a ball in a continuous throw-and-catch loop.
A joystick-conditioned quadruped policy trained across 8,192 environments.
Coordinated balance, locomotion, and manipulation for a full-body humanoid policy.
Spaces collect live runs, trained checkpoints, and visual evaluations from our ongoing robotics work. New environments will appear here as they come online.